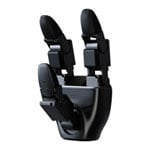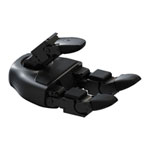


Unitree Dex 3-1 Tactile Three Fingered Right Hand for H2 Robot
Unitree Dex 3-1 Tactile Robotic Hand, Right Hand for H2 Humanoid, 3 Fingers, 7 Degrees of Freedom, 33 Sensors, 500g Load
Email me when the availability or price changes
A Dexterous Hand That Can Operate Anything
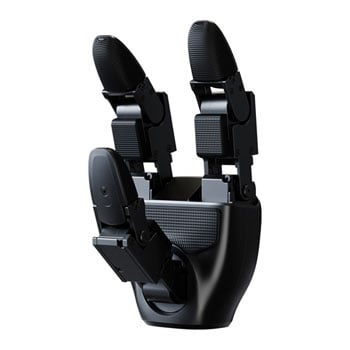
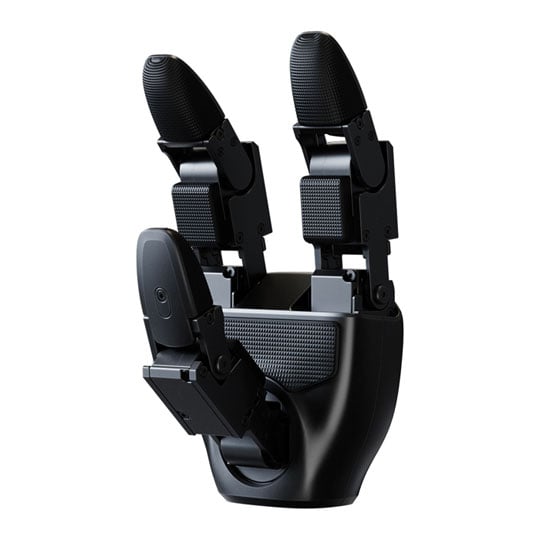
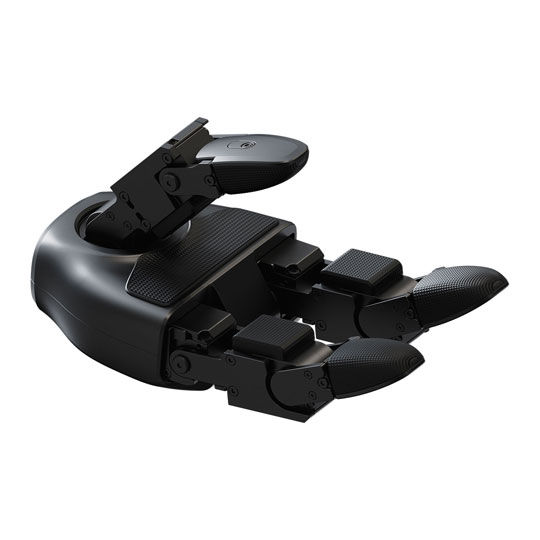
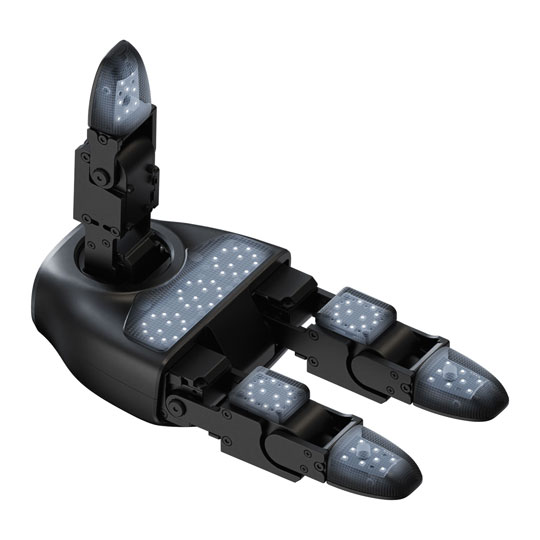
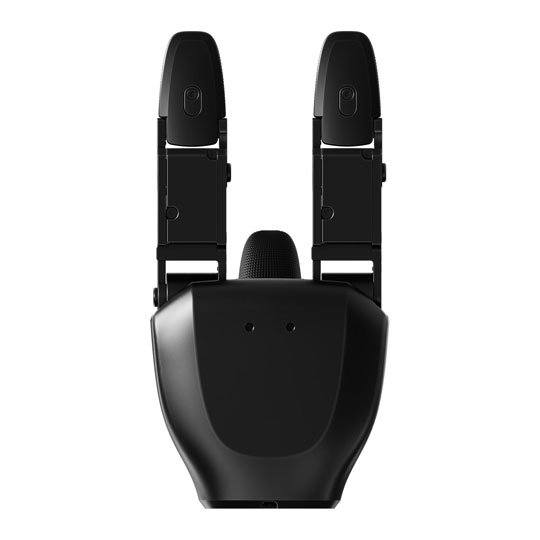
The Unitree Dex3-1 is a three-finger dexterous robotic hand featuring 7 degrees of freedom across the thumb, index finger and middle finger. It uses six miniature brushless force-control joints with direct drive and one miniature brushless force-control joint with gear drive to support controlled finger movement.
Tactile Sensing
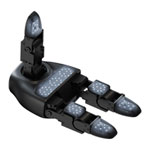
Equipped with 33 tactile pressure sensors across nine sensor arrays, the Dex3-1 provides pressure sensing across the palm, finger pads and fingertips. Its perception range is 10–2,500 g, with a communication rate of 1,000 Hz, supporting detailed tactile feedback during object handling.
Gripping Capability
Under the specified test conditions of room temperature, palm facing down and grasping a 5 cm round, hard object, the Dex3-1 supports a maximum grasped weight of 500 g. Its maximum power is rated at 400 W for 3 seconds.
Performance and Connectivity
The Dex3-1 offers fingertip repeat positioning accuracy of ±2 mm, a working voltage of 12–58 V and a USB 2.0 communication interface. With an operating temperature range of -20°C to 60°C, it supports a broad range of operating environments. These capabilities make it suitable for robotic tasks that require repeatable finger positioning and controlled object handling, such as picking up small objects, manipulating components and performing dexterous movements.
Please Note: This is a left hand variant with dedicated mounting for the H2 humanoid only.
• Three-finger dexterous robotic hand with 7 degrees of freedom for complex object manipulation.
• 33 tactile pressure sensors across nine sensor arrays, with a perception range of 10–2,500g.
• ±2mm fingertip repeat positioning accuracy for controlled, repeatable movements.
• Six direct-drive and one gear-driven miniature brushless force-control joints.
• Maximum grasped weight of 500g under specified test conditions.
• Joint position, velocity, torque, temperature and pressure sensor feedback, with adjustable stiffness and damping control.
• 1,000Hz communication rate for tactile sensing and joint control.
• 12–58V working voltage and USB 2.0 communication interface.
• Operating temperature range of -20°C to 60°C.
• Compact 710g design measuring 175 × 88 × 77mm.