Physical AI
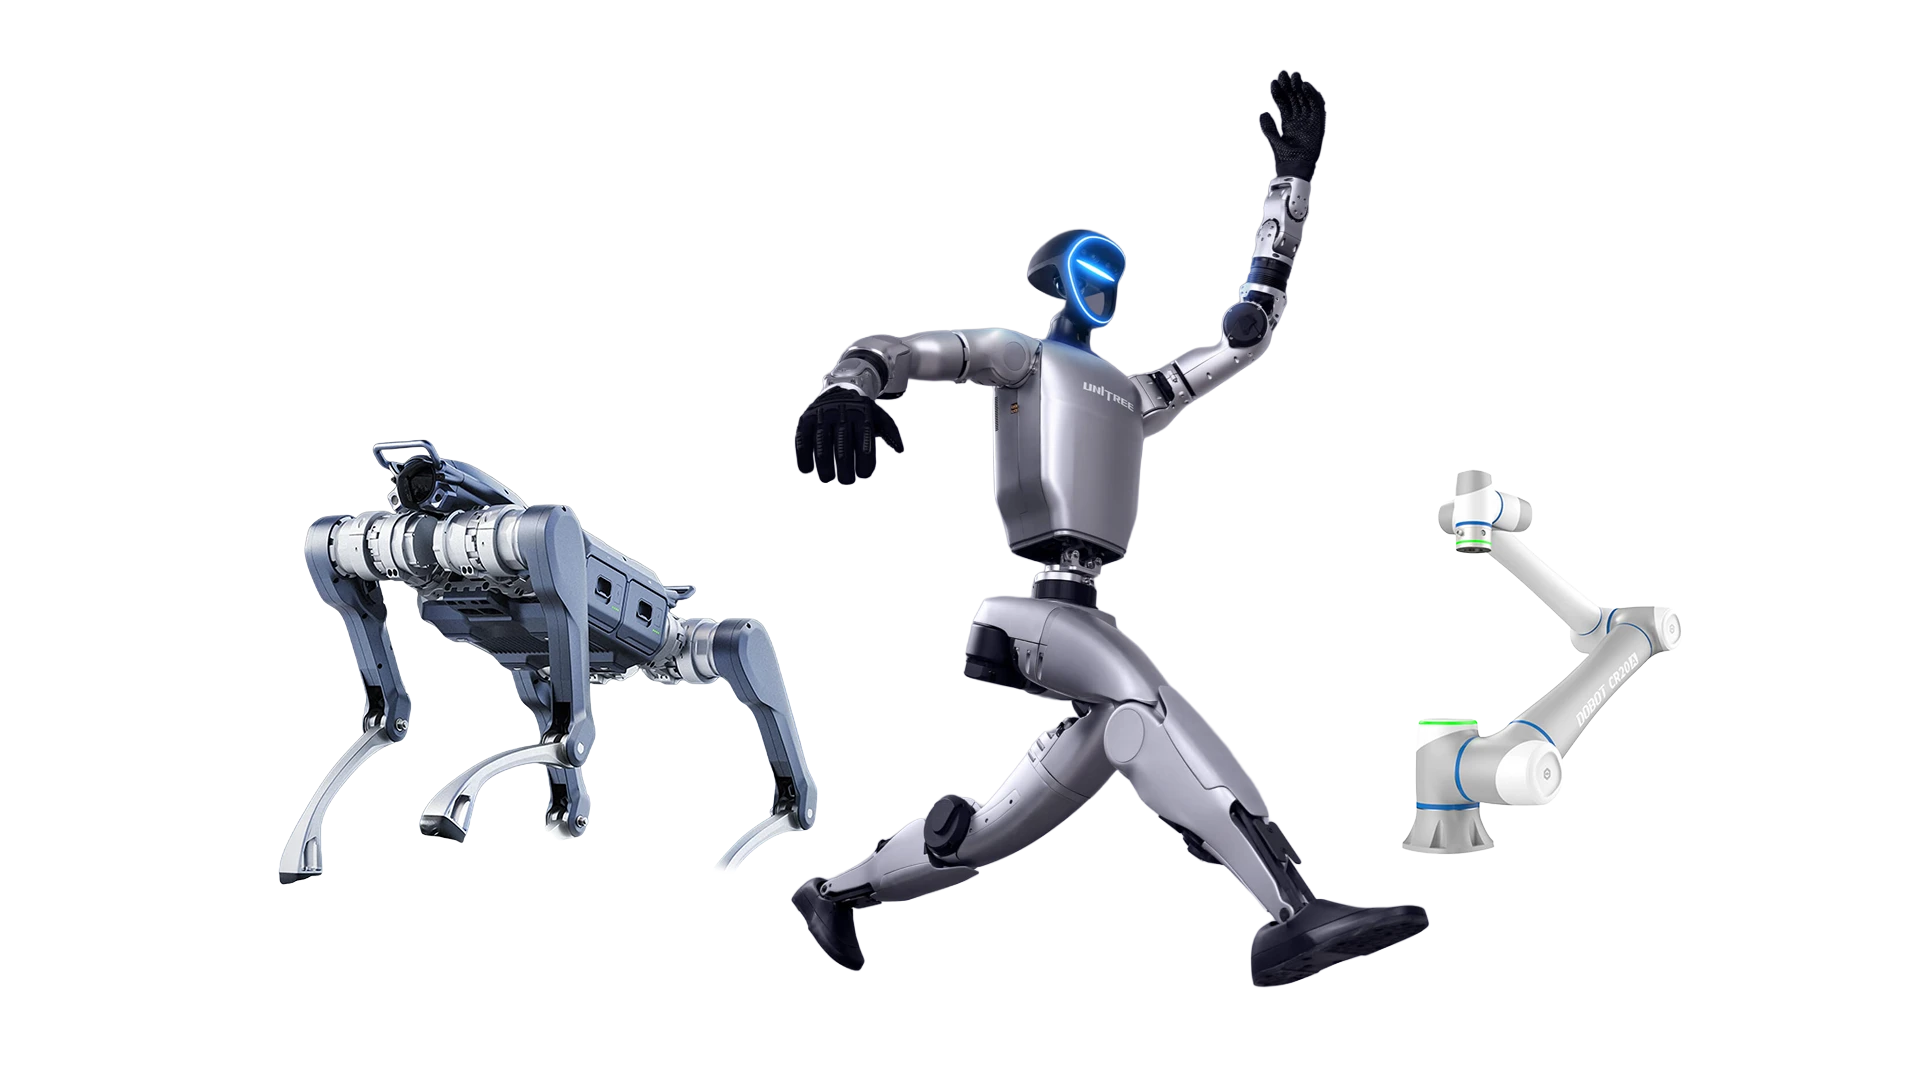
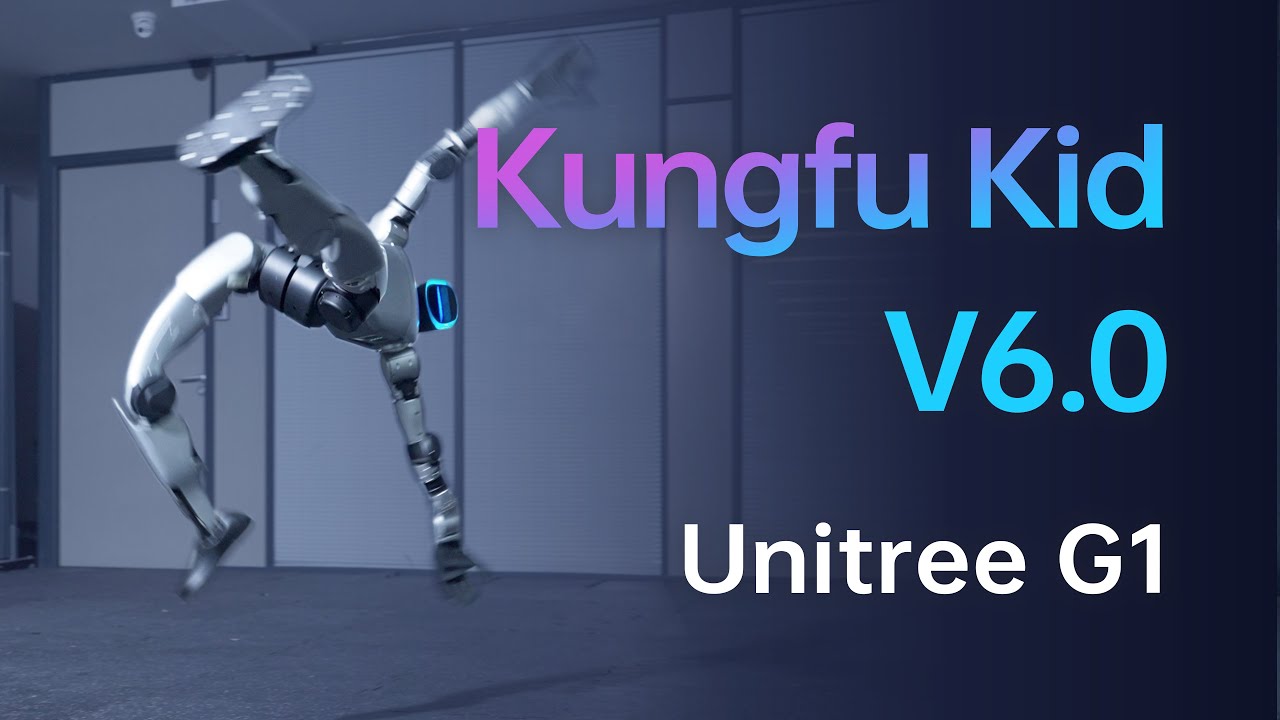
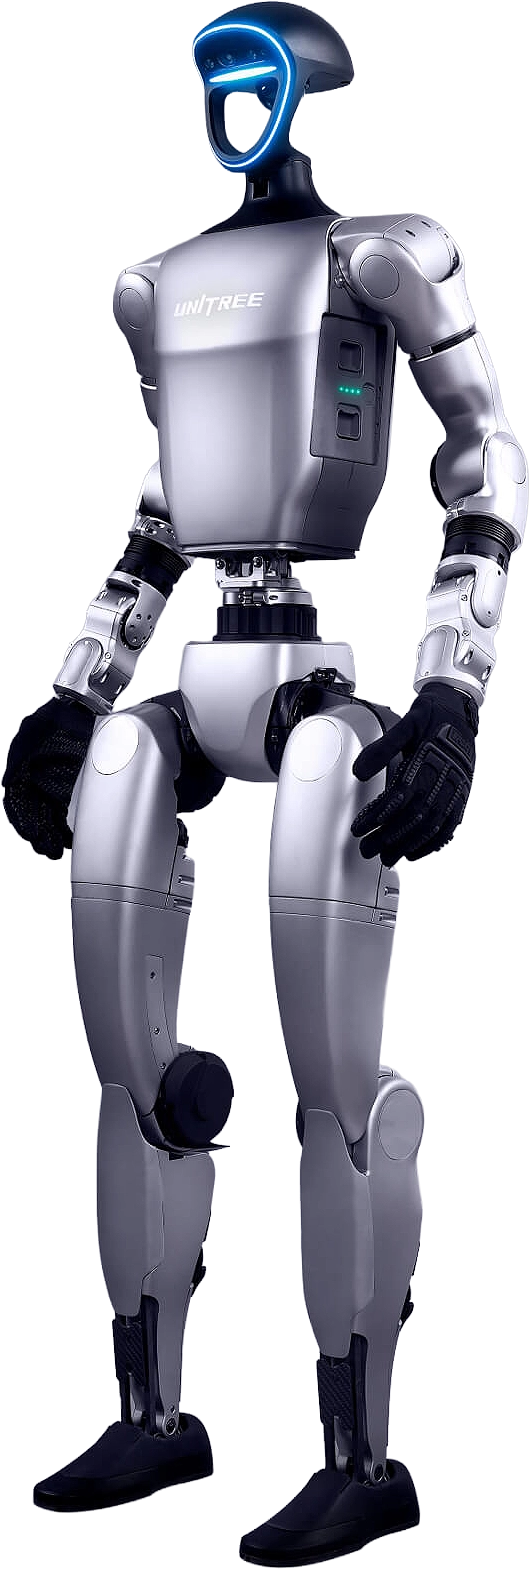
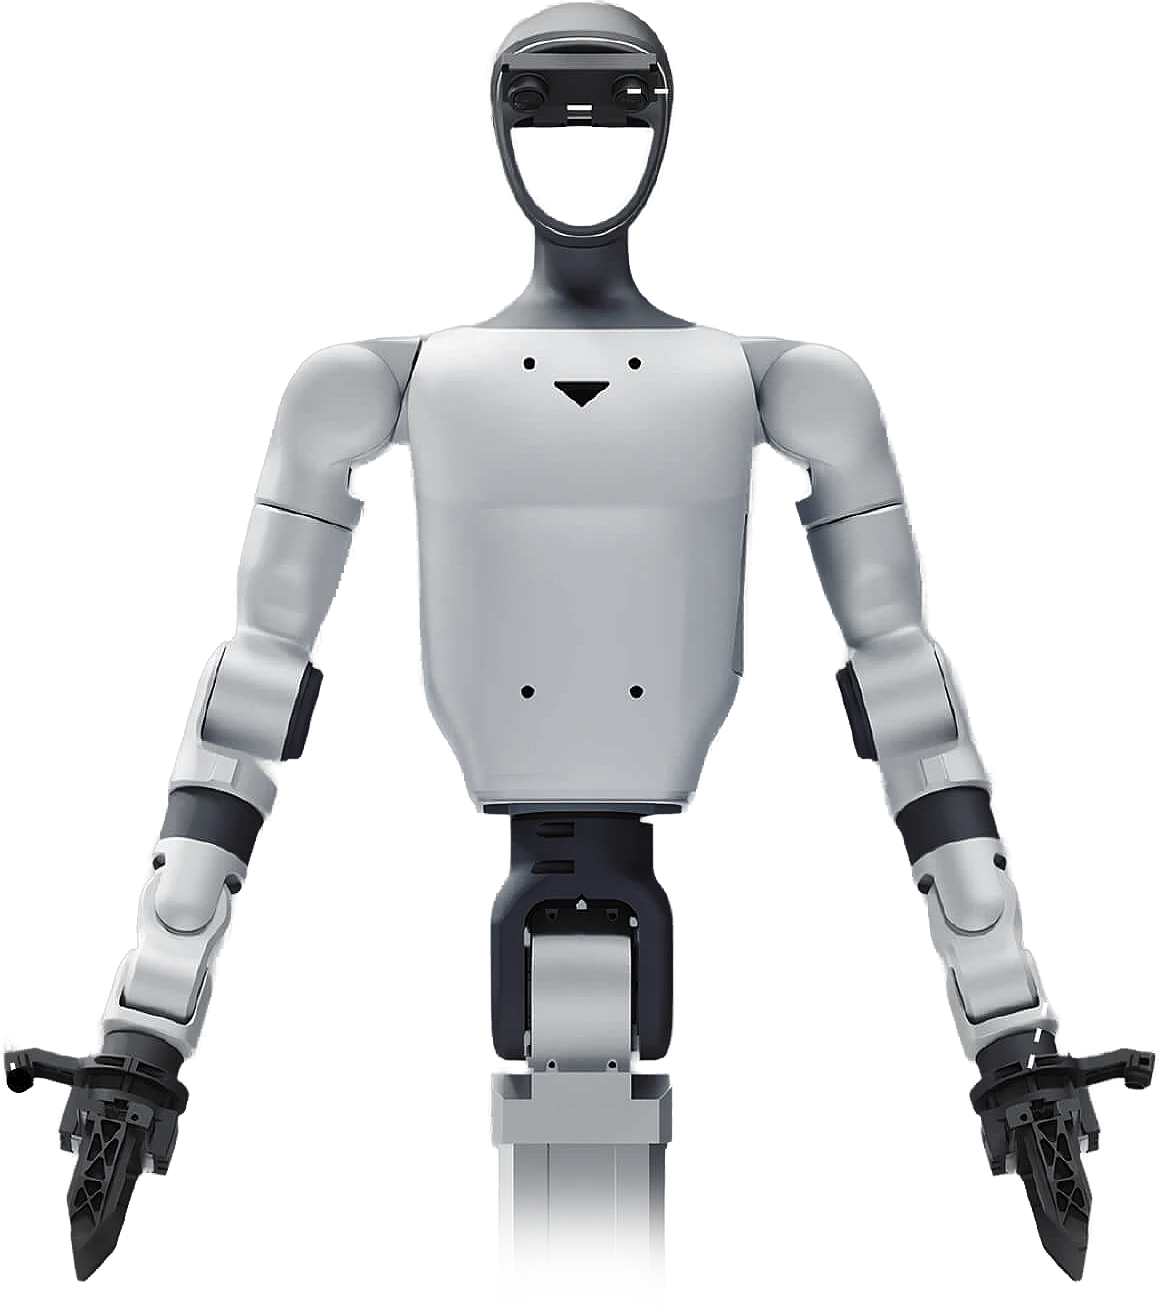
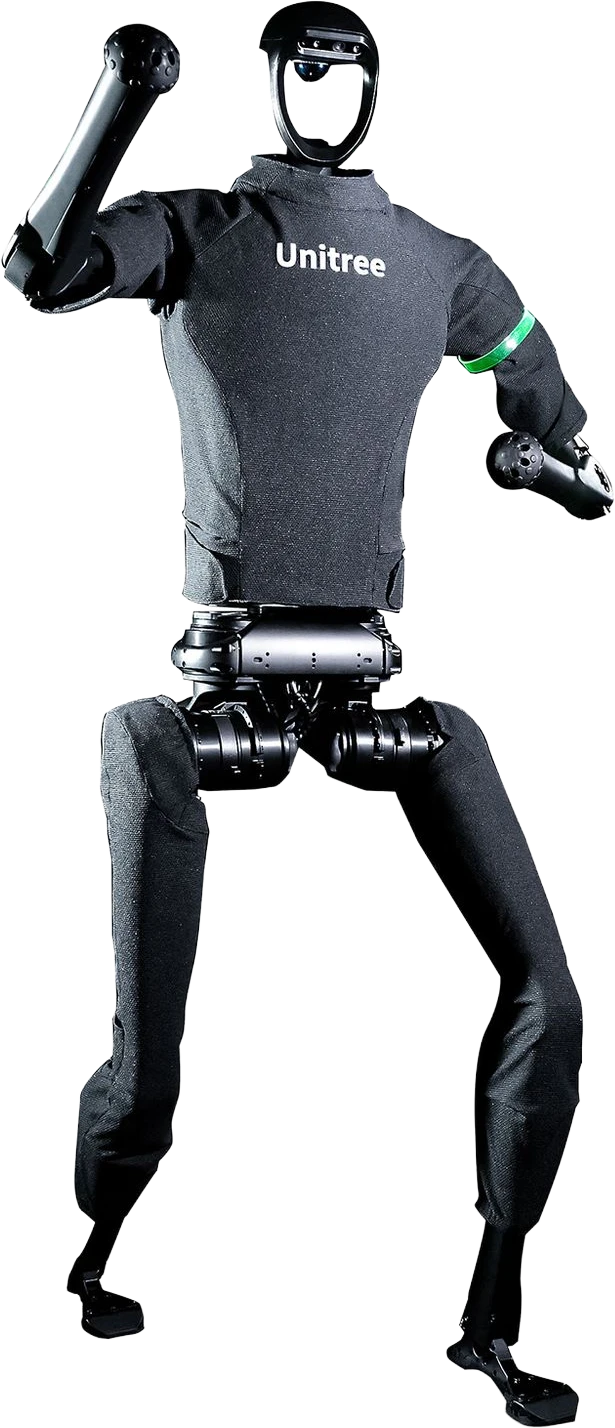
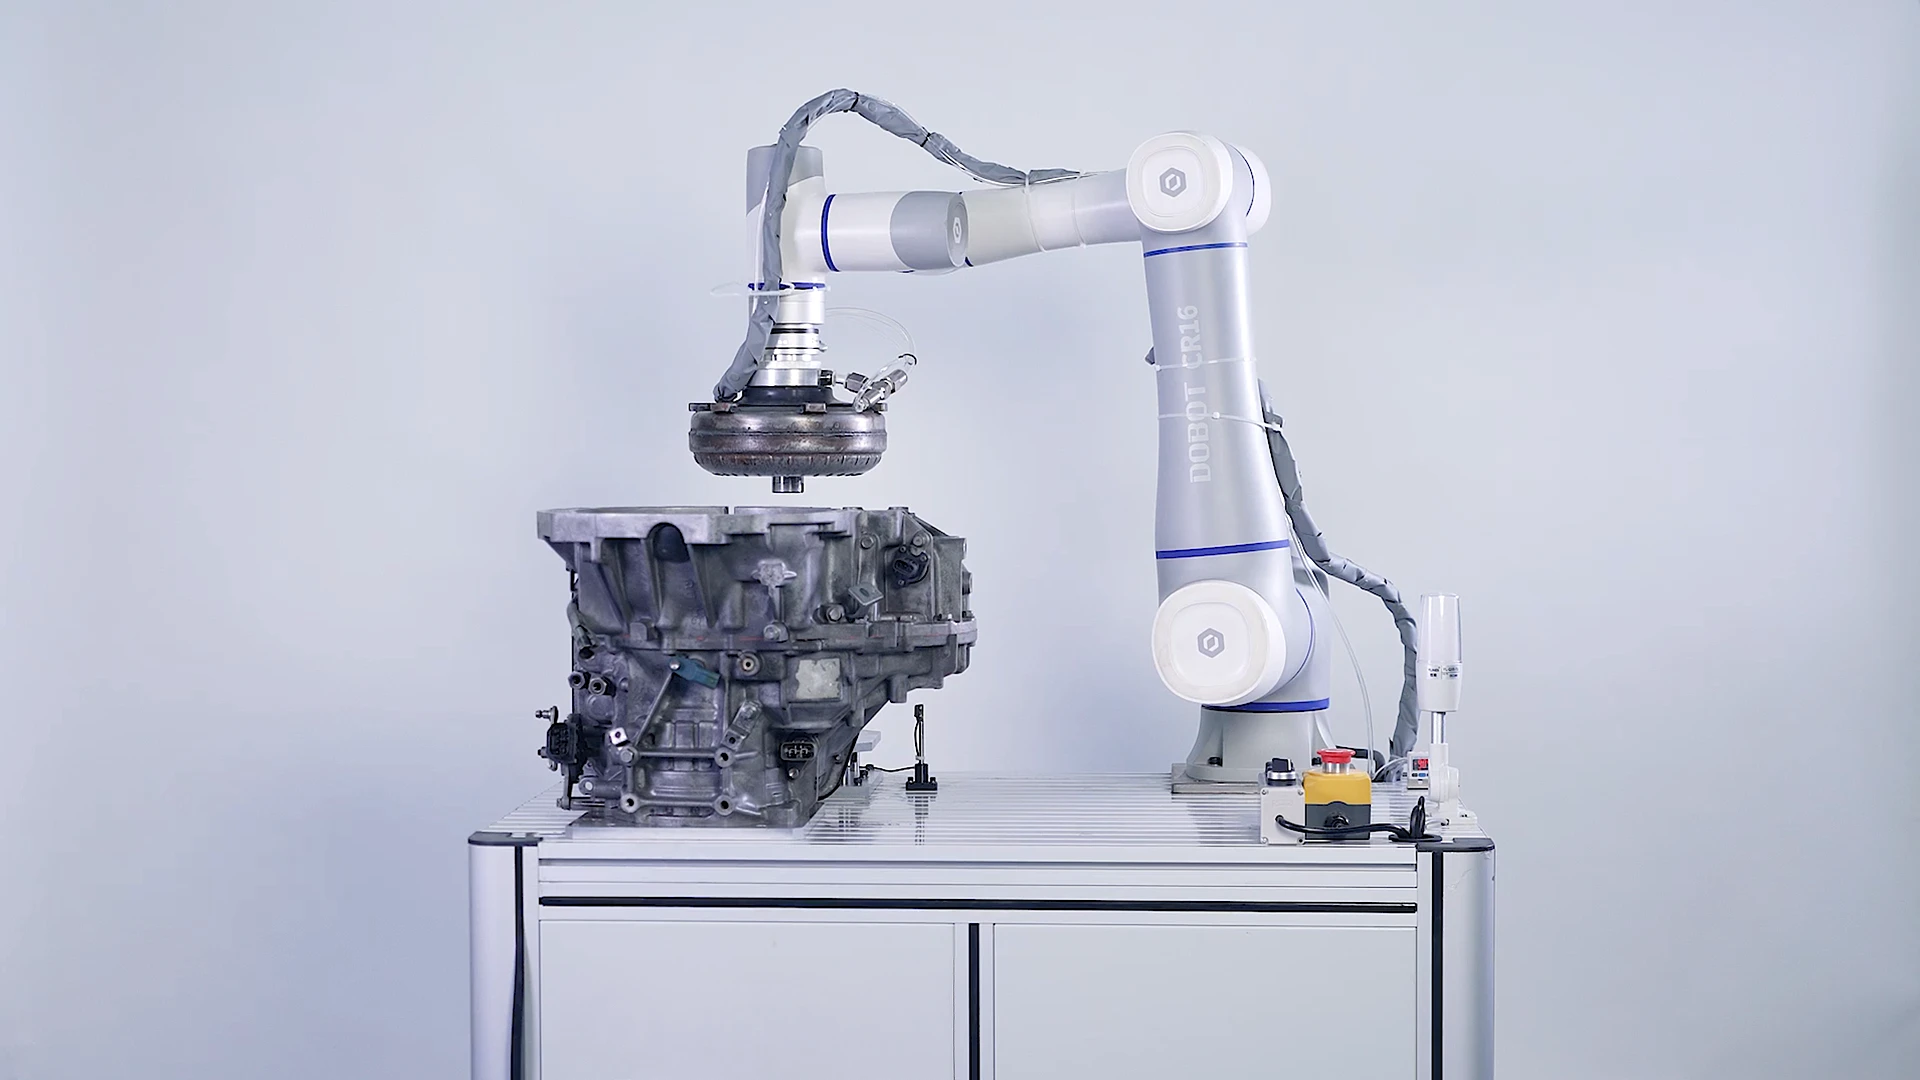
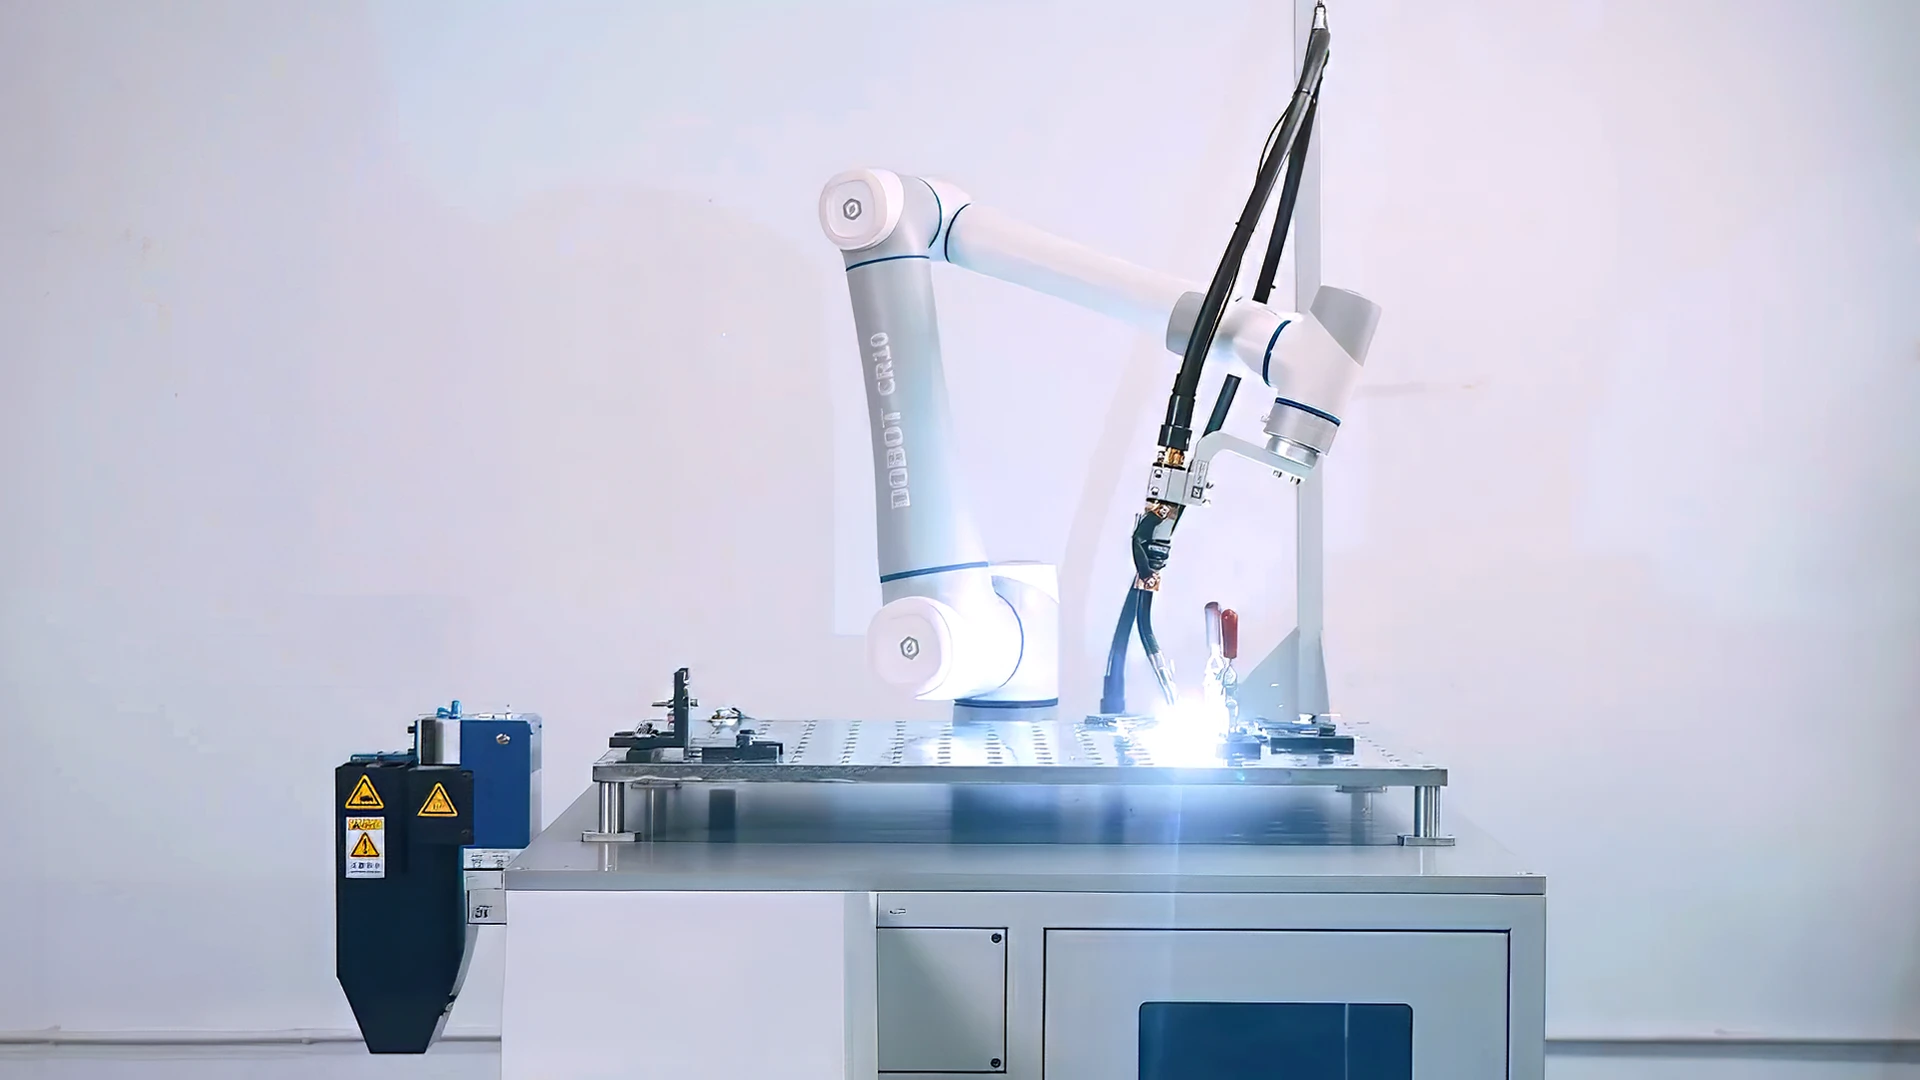
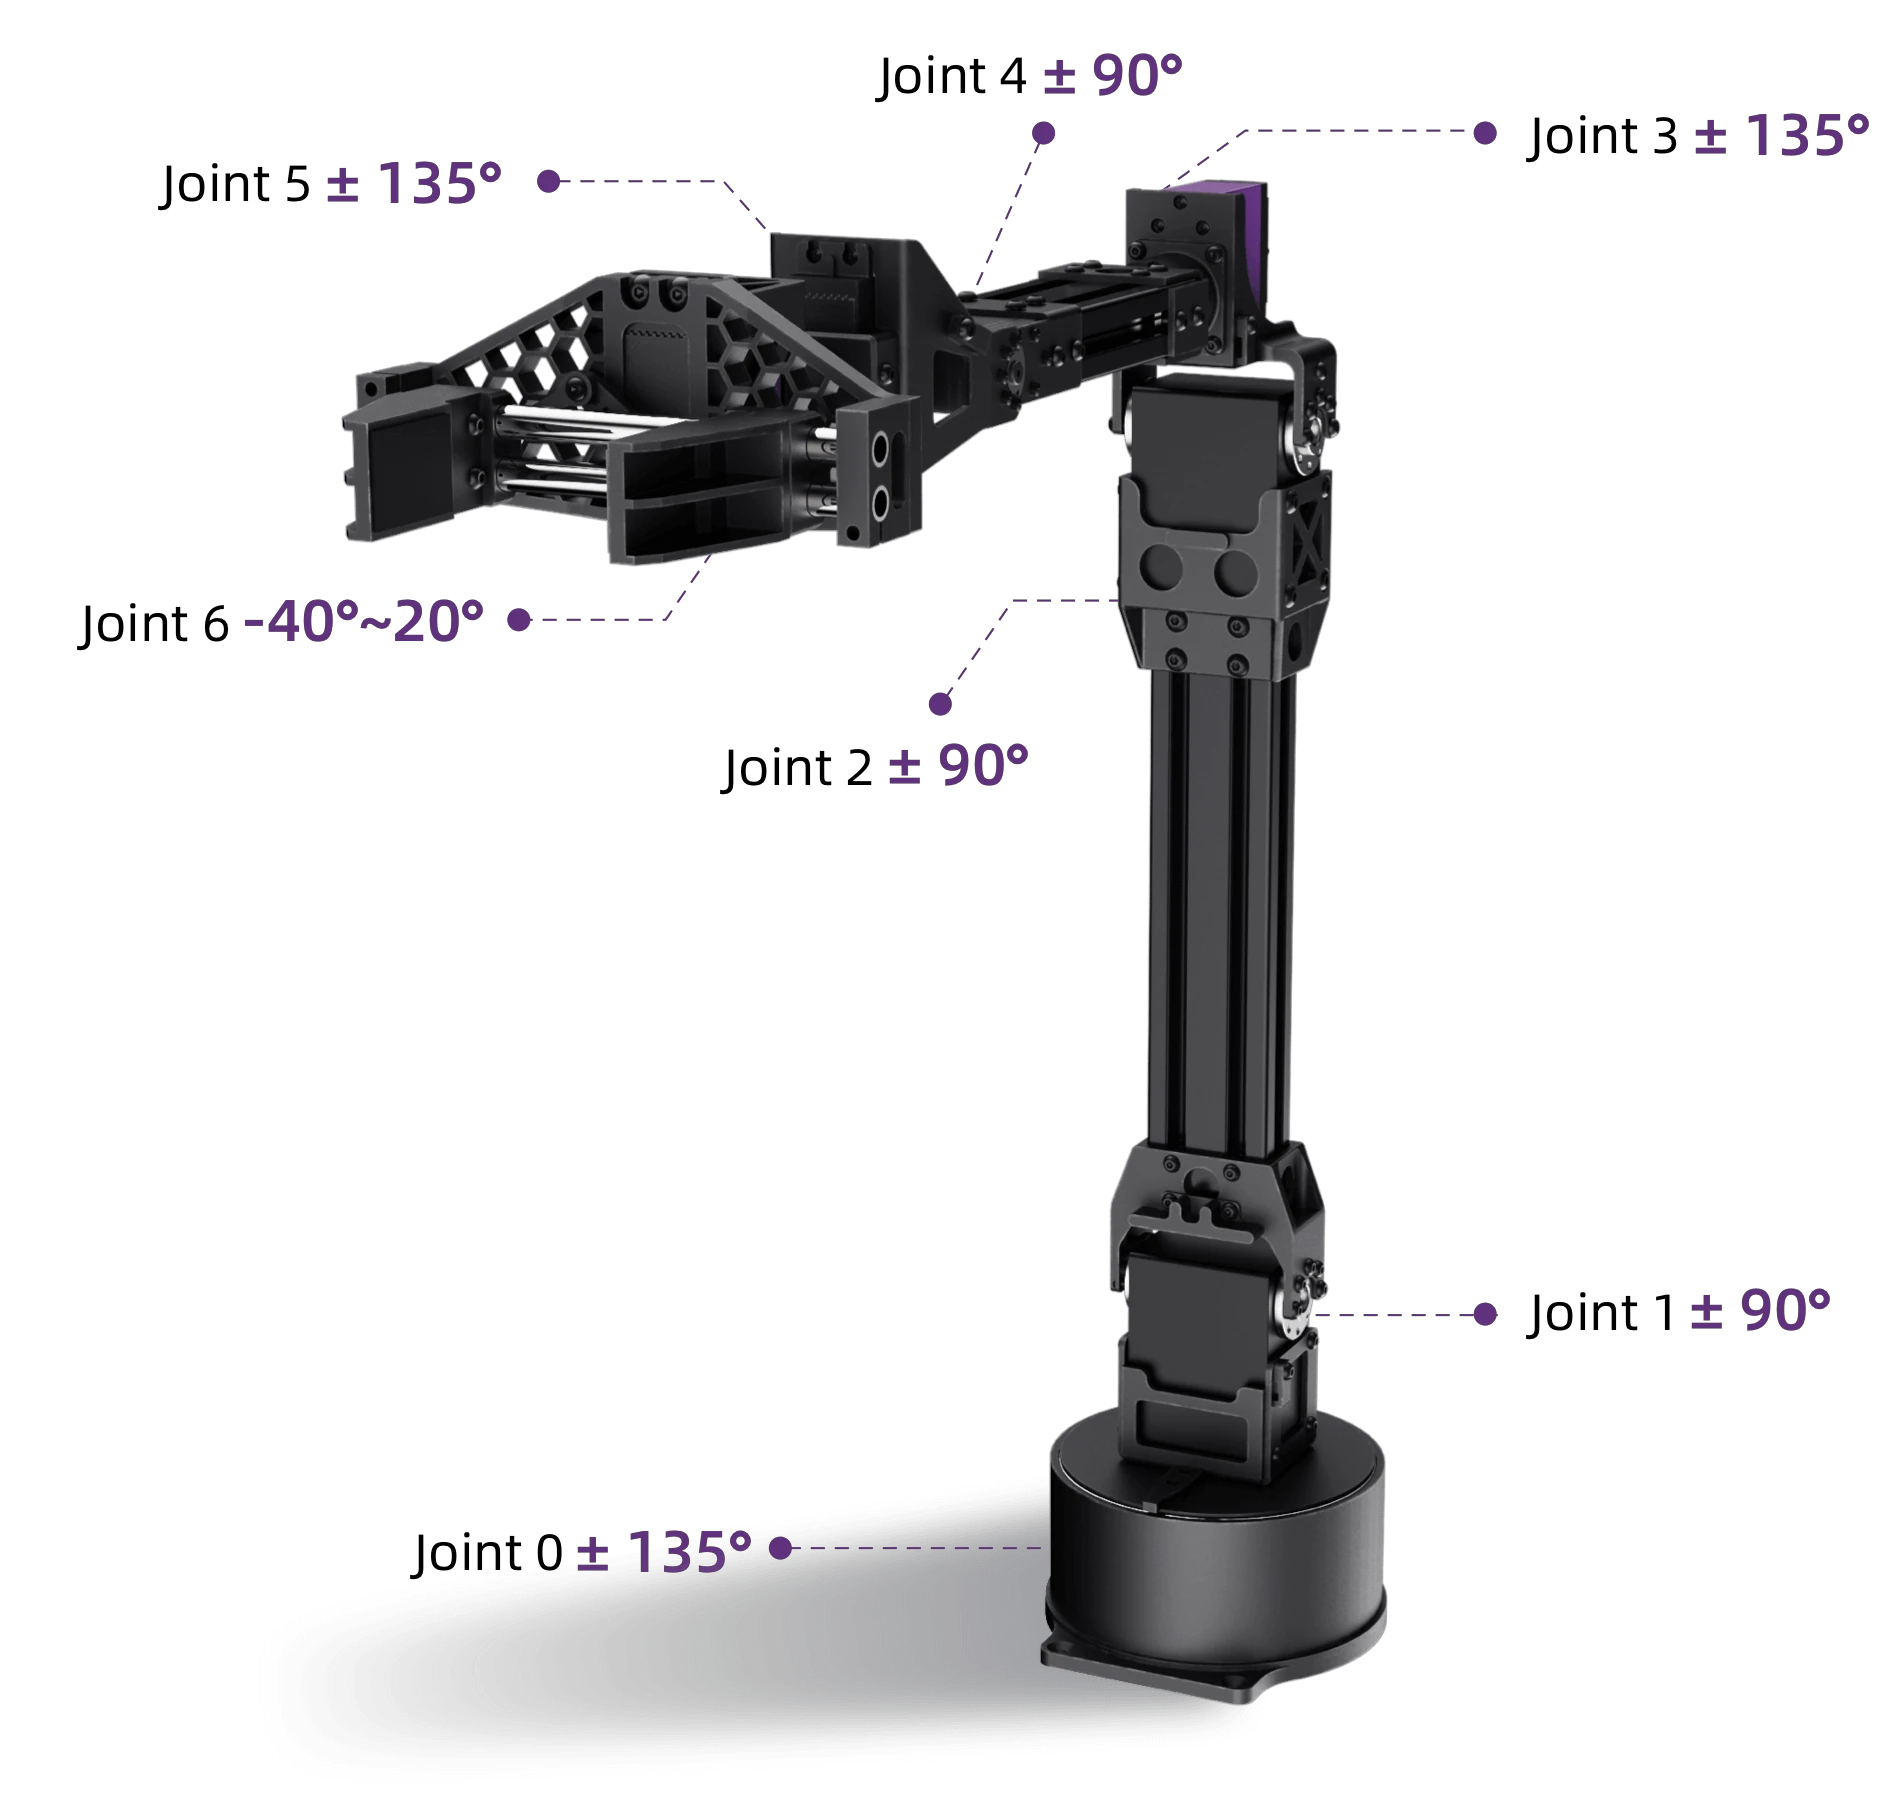
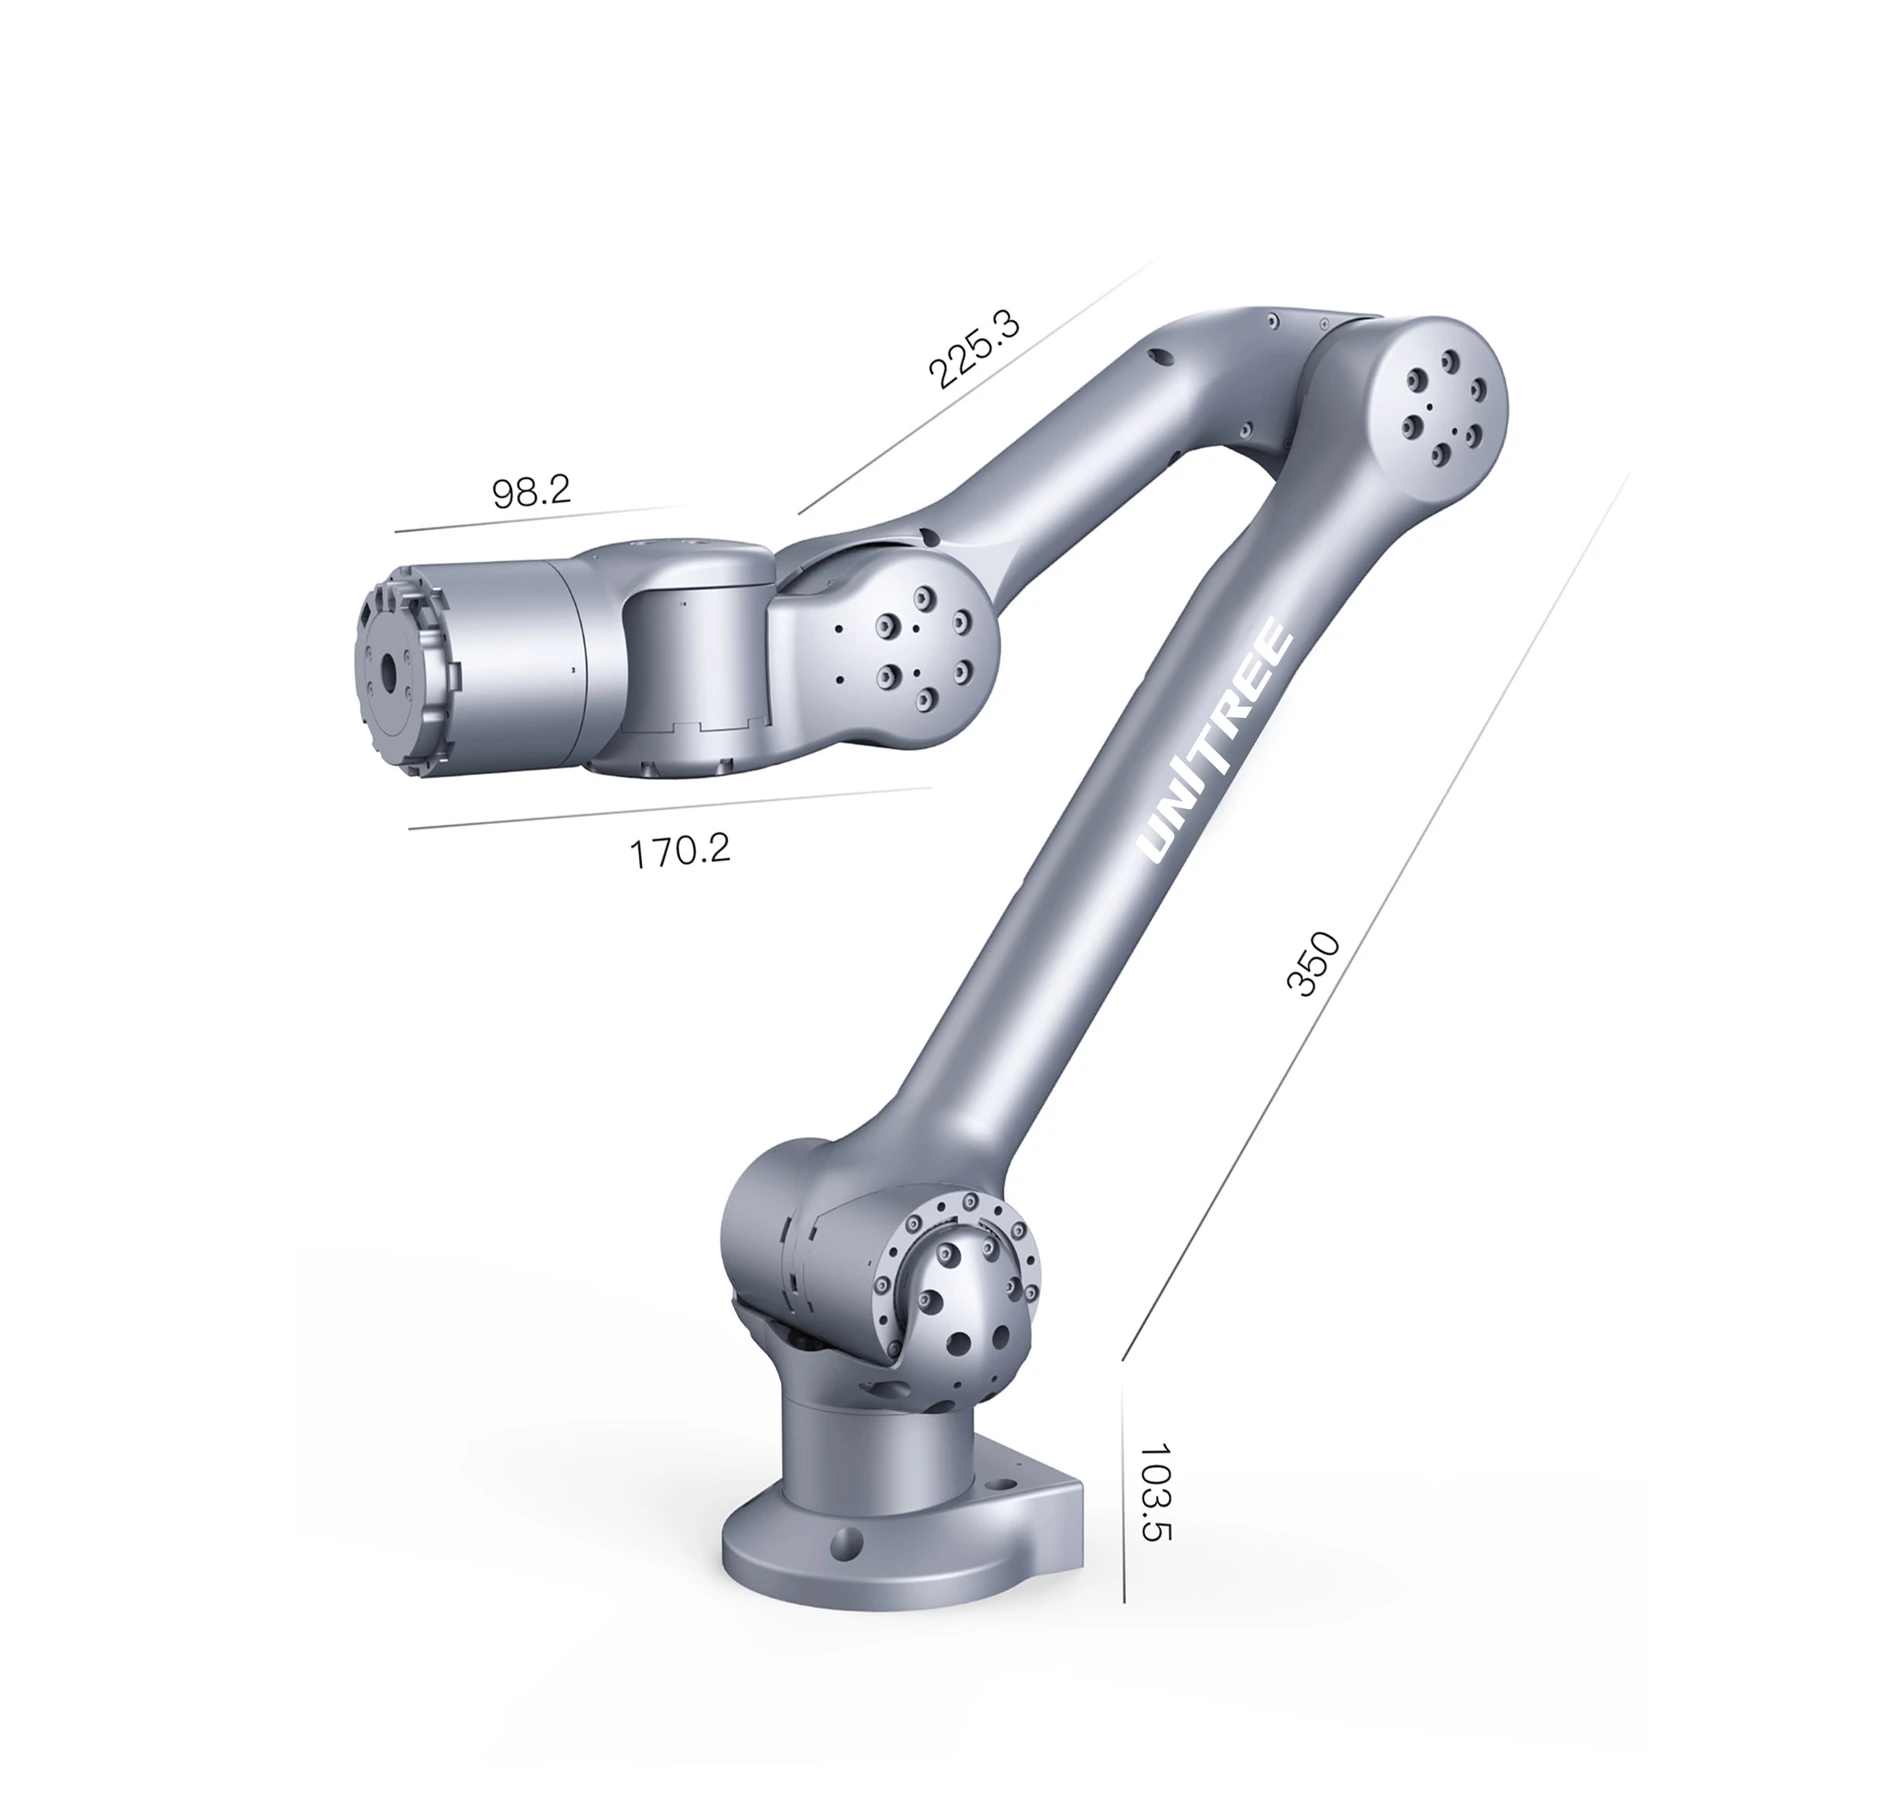
We mentioned physical AI at the start of this guide, but let’s recap. Physical systems (humanoid robots, quadruped
robots or robotic arms) capture and process information from their sensors and actuators to perform their
functions. However, if you want to introduce any degree of AI automation and learning, especially in complex
environments then the data and processing demands demand a whole other level of performance. This is often
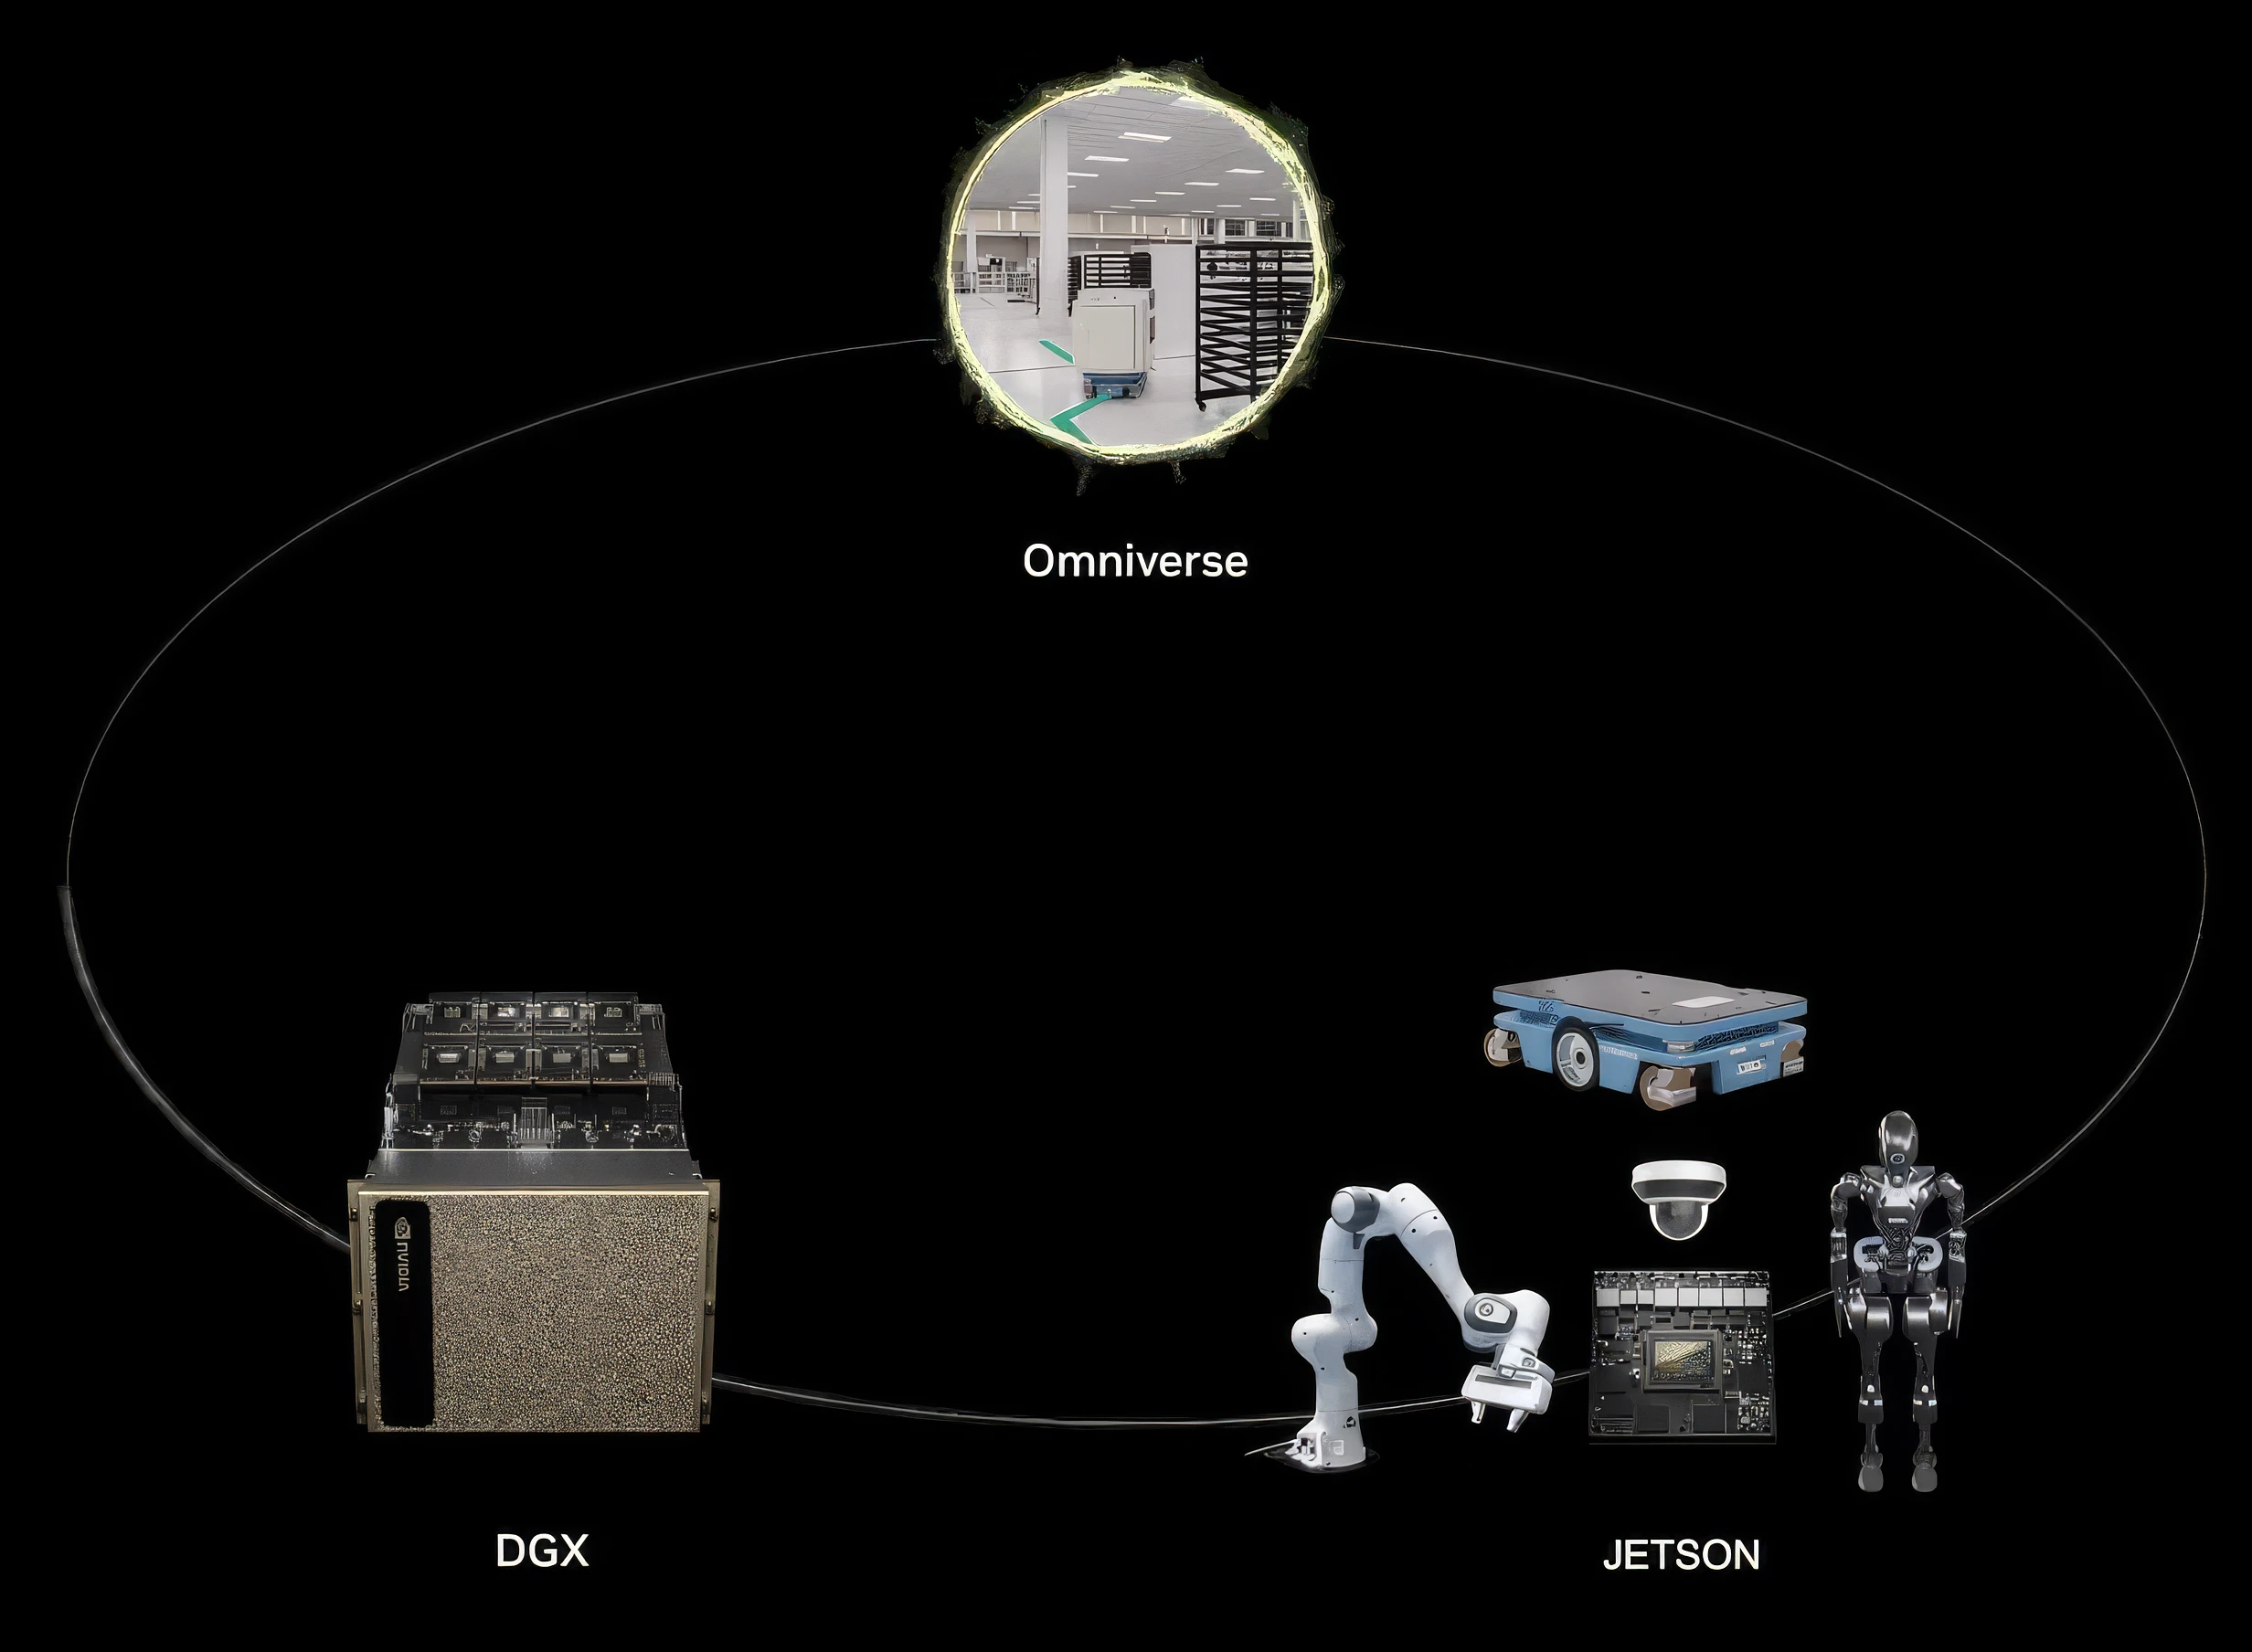
referred to as the three-computer problem, or the three-computer solution, as three distinct levels of compute are
required to achieve this - NVIDIA DGX, NVIDIA Omniverse and NVIDIA Jetson.
To explain why AI robotic systems are much more complicated than other types of AI model, imagine an algorithm
designed to recognise five types of cooking utensil. This requires training a model to recognise cooking utensils
and a camera sensor to see the various types. Now add in the ability to pick up these utensils and use them - the
camera element now needs the addition of robotic arms and further training of how each utensil is used.
Now add mobility so the robot can recognise, pick up and use the utensil, but only in the correct kitchen location
- this adds more training on processes plus a spatial understanding of its environment. Finally, make the robot
work in a crowded kitchen where it may be obstructed or knocked off balance mid-task - the training now needs to
include how to negotiate obstacles and how to recover an interrupted task, without causing injury as some
collisions may be with softer humans rather than harder surfaces.
You can see how the additional layers of complexity at each stage require a whole new level of training data and
parameters to give the robot any chance of success. This is where the three computers come in - firstly, powerful
multi-GPU DGX SYSTEMS are required to train datasets so large to scale and then fine-tune the model. Next, RTX PRO
SERVERS - designed for advanced visualisation tasks - support the OMNIVERSE real-time collaboration cloud
platform.
This enables simulation of the environments and human-robot interactions, so all scenarios can be tried and
tested. Most importantly, mistakes and errors can be ironed out in the Omniverse digital twin so costly real-world
mishaps can be avoided. Finally, and as mentioned above in the humanoid and quadruped robot tabs, onboard JETSON
modules allow the finalised model to be deployed directly on the robot so it can perform as intended.
Read More