
Unitree Dex 1-1 Standard
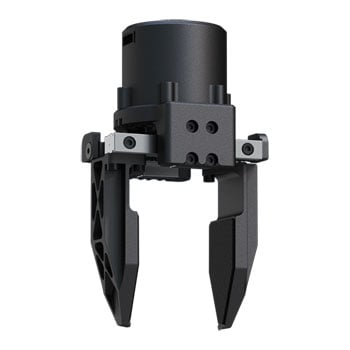
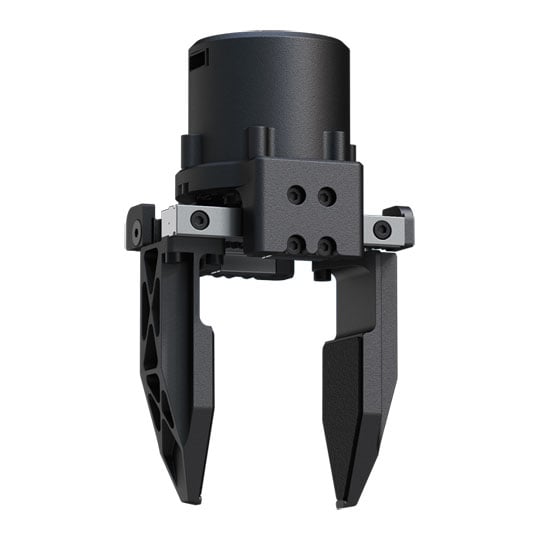
The Unitree Dex1-1 Standard is a robotic gripper featuring a 90mm stroke and 80mm jaw length, allowing it to grasp a wide range of objects. It features an alloy casing, refined gripper tips and a built-in camera ring for embodied AI applications.
Gripping Force and Speed
Powered by a self-developed robotic joint motor, the Dex1-1 delivers an adjustable gripping force of 5–120N and an adjustable speed of 50–375mm/s. With 0.1mm fingertip position resolution and a full-stroke closing time of 0.24 seconds, it supports fast, controlled gripping. Its rated grasp load reaches 20kg for form-fitting grasps and 5kg for friction-based grasps.
Motor Control and Communication
The Dex1-1 supports position, velocity, torque, stiffness and damping control, enabling adjustable gripping behaviour. It uses a high-speed 485 communication protocol with a baud rate of 6Mbps and a communication control frequency of 1,000Hz.
Electrical and Operating Specifications
Operating at 24–64V, with 24V or 48V DC recommended, the gripper has a static current of 0.03A and a peak line current of 3.5A. Its motor delivers 5Nm peak torque, with a maximum speed of 27rad/s when supplied with 64V. A 1:25 reduction ratio and 15-bit absolute encoder support motor control and position feedback.
Feedback and Operating Environment
Motor status feedback includes angle, angular velocity, torque and temperature, supporting controlled pick-and-place operations, object handling and repetitive gripping tasks. The two-finger design is well suited to grasping, lifting and repositioning individual components or objects. With a recommended operating temperature range of -20°C to 60°C, the Dex1-1 supports a broad range of working environments.
Please Note: This is a right hand variant with dedicated mounting for the G1 humanoid only.
• Two-finger robotic gripper with 1 degree of freedom for basic object handling.
• Refined gripper tips and built-in camera ring.
• 90mm stroke and 80mm jaw length for grasping a wide range of objects.
• Adjustable gripping force of 5–120N and speed of 50–375mm/s.
• 0.1mm fingertip position resolution for controlled, repeatable gripping.
• Self-developed robotic joint motor with 5Nm peak torque and maximum rotational speed of 27rad/s at 64V.
• Maximum grasp load of 20kg for form-fitting grasps and 5kg for friction-based grasps.
• Position, velocity, torque, stiffness and damping control, with motor feedback for angle, angular velocity, torque and temperature.
• High-speed 485 communication protocol, 6Mbps baud rate and 1,000Hz control frequency.
• 24–64V working voltage, with 24V or 48V DC recommended.
• Recommended operating temperature range of -20°C to 60°C.