
Unitree Dex 1-1 Plus Two-Fingered Left Gripper for G1 Robot
Unitree Dex 1-1 Plus Robotic Gripper, Left Hand for G1 Humanoid, 2 Fingers, 1 Degree of Freedom, RGB Camera, 20kg Load
Email me when the availability or price changes
Unitree Dex 1-1 Plus
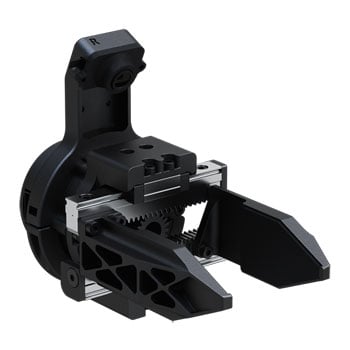
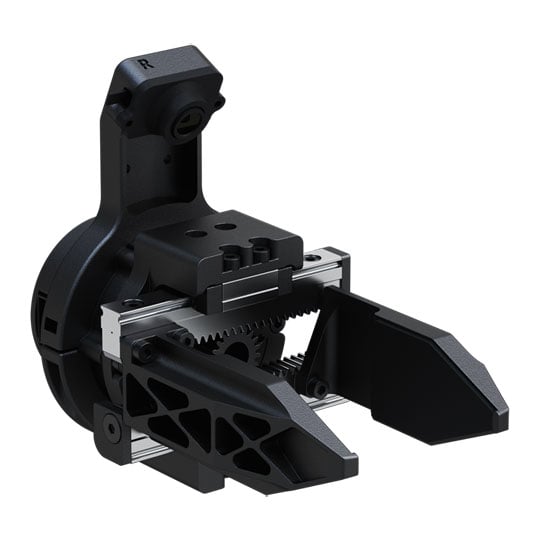
The Unitree Dex1-1 Plus is a two-finger robotic gripper featuring a 90mm stroke and 80mm jaw length for grasping a wide range of objects. It features an alloy casing, refined gripper tips and an RGB camera with a 160° field of view. The camera mount supports visual sensing for embodied AI applications.
Gripping Force and Speed
Powered by a self-developed robotic joint motor, the Dex1-1 Plus delivers an adjustable gripping force of 5–120N and an adjustable speed of 50–375mm/s. With 0.1mm fingertip position resolution and a full-stroke closing time of 0.24 seconds, it supports fast, controlled gripping. Its rated grasp load reaches 20kg for form-fitting grasps and 5kg for friction-based grasps.
Motor Control and Communication
The Dex1-1 Plus supports position, velocity, torque, stiffness and damping control, allowing gripping behaviour to be adjusted for different tasks. It uses a high-speed RS485 communication protocol with a baud rate of 6Mbps and a control frequency of 1,000Hz.
160° RGB Camera
The Plus variant adds an RGB camera with a 160° field of view and a dedicated camera mount. Included accessories comprise a D405 depth camera mount (depth camera not included), an RS485-to-USB adapter and connecting cables. This provides the hardware for camera mounting and communication, with the user responsible for installation.
Electrical and Operating Specifications
Operating at 24–64V, with 24V or 48V DC recommended, the gripper has a static current of 0.03A and a peak line current of 3.5A. Its motor delivers 5Nm peak torque, with a maximum speed of 27rad/s at 64V. A 1:25 reduction ratio and 15-bit absolute encoder support motor control and position feedback.
Feedback and Compatibility
Motor status feedback includes angle, angular velocity, torque and temperature, supporting controlled pick-and-place operations, object handling and repetitive gripping tasks. The two-finger design is suited to grasping, lifting and repositioning individual components or objects.
Please Note: This is a left hand variant with dedicated mounting for the G1 humanoid only.
• Two-finger robotic gripper with 1 degree of freedom and an integrated camera platform for visual sensing.
• RGB camera with a 160° field of view and dedicated camera mount.
• 90mm stroke and 80mm jaw length for grasping a wide range of objects.
• Adjustable gripping force of 5–120N and speed of 50–375mm/s.
• 0.1mm fingertip position resolution for controlled, repeatable gripping.
• Self-developed robotic joint motor with 5Nm peak torque and maximum rotational speed of 27rad/s at 64V.
• Maximum grasp load of 20kg for form-fitting grasps and 5kg for friction-based grasps.
• Position, velocity, torque, stiffness and damping control, with motor feedback for angle, angular velocity, torque and temperature.
• High-speed RS485 communication protocol, 6Mbps baud rate and 1,000Hz control frequency.
• 24–64V working voltage, with 24V or 48V DC recommended.
• Recommended operating temperature range of -20°C to 60°C.
• Includes D405 depth camera mount (D405 camera not included), RS485-to-USB adapter and cables.