
Unitree BrainCo Revo 2 Touch Five Fingered Right Hand for G1 Robot
Unitree BrainCo Revo 2 Touch Robotic Hand, Right Hand for G1 Humanoid, 5 Fingers, 11 Degrees of Freedom, 20kg Load
Email me when the availability or price changes
Bionic Dexterous Hand with Multimodal Tactile Sensing
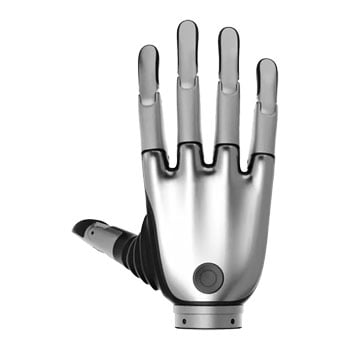
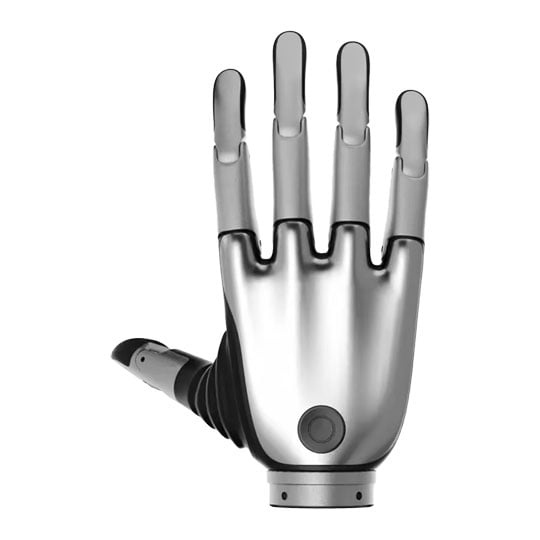
The BrainCo Revo 2 Touch is a bionic dexterous hand for robot integration and research, combining 6 active joints with 11 degrees of freedom. Its five-finger configuration supports a range of grasping and manipulation tasks, while its multimodal tactile sensing detects pressure, friction, direction and proximity. The hand weighs 383g and measures 160mm in height.
Finger Movement and Gripping Performance
The Revo 2 Touch features a thumb with 59° of flexion and 90° of auxiliary movement, alongside 81° of movement for each of the index, middle, ring and little fingers. It delivers a whole-hand grip force of 50N and a single-finger pinch force of 15N, with a repeat control accuracy of 0.1°. The maximum opening and closing distance is 100mm, measured from the thumb to the index finger.
Multimodal Tactile Feedback and Control
A multidimensional fingertip tactile module provides pressure, friction, direction and proximity sensing. The hand supports position, velocity and current feedback control, alongside cascaded control, compliance control and tactile adaptive control. These capabilities support responsive interaction with objects and adaptive gripping behaviour.
Turbo Mode and Calibration
Turbo mode uses stall detection to manage gripping against objects. When a finger stalls against an object, it pauses for a configured duration before continuing to grip at 500ms intervals. This mode can support gripping soft or shifting objects. On power-up, automatic calibration moves all fingers through a position sweep to establish their starting origin bounds.
Communication and Software Support
The Revo 2 Touch supports RS485, CAN FD and EtherCAT communication interfaces, with the interface located below the wrist. It is compatible with Linux, Windows and ROS workflows, and supports Python and C development. SDK support, closed-loop servo control and custom gesture definitions provide options for developing and controlling robotic hand applications.
Electrical Specifications and Protection
The hand operates on a supply voltage of 12–64V. At 24V, static current is 115mA, average no-load current during five-finger flexion and extension is 390mA, and maximum current is 4.65A. Built-in protection features include current protection, stall protection, high-temperature protection and anti-collision protection.
Please Note: This is a right hand variant with dedicated mounting for the G1 humanoid only.
• Five-finger bionic dexterous hand with 6 active joints and 11 degrees of freedom for robotic manipulation.
• Multimodal tactile sensing for pressure, friction, direction and proximity detection.
• 0.1° repetitive control accuracy for controlled, repeatable finger movements.
• Whole-hand grip force of 50N and single-finger pinch force of 15N.
• Maximum opening distance of 100mm between the thumb and index finger.
• Position, velocity and current feedback control, with cascaded, compliance and tactile adaptive control.
• RS485, CAN FD and EtherCAT communication interfaces for robotic control.
• 12–64V supply voltage, with a maximum current of 4.65A at 24V.
• Compatible with Python, C, Linux, Windows and ROS workflows, with SDK support and custom gesture definitions.
• Built-in current, stall, high-temperature and anti-collision protection.
• Turbo mode with stall detection and configurable pauses for continued gripping of soft or shifting objects.
• Automatic power-on calibration to establish finger origin positions.
• Compact 383g design measuring 160mm in height.